Illustration & research credits
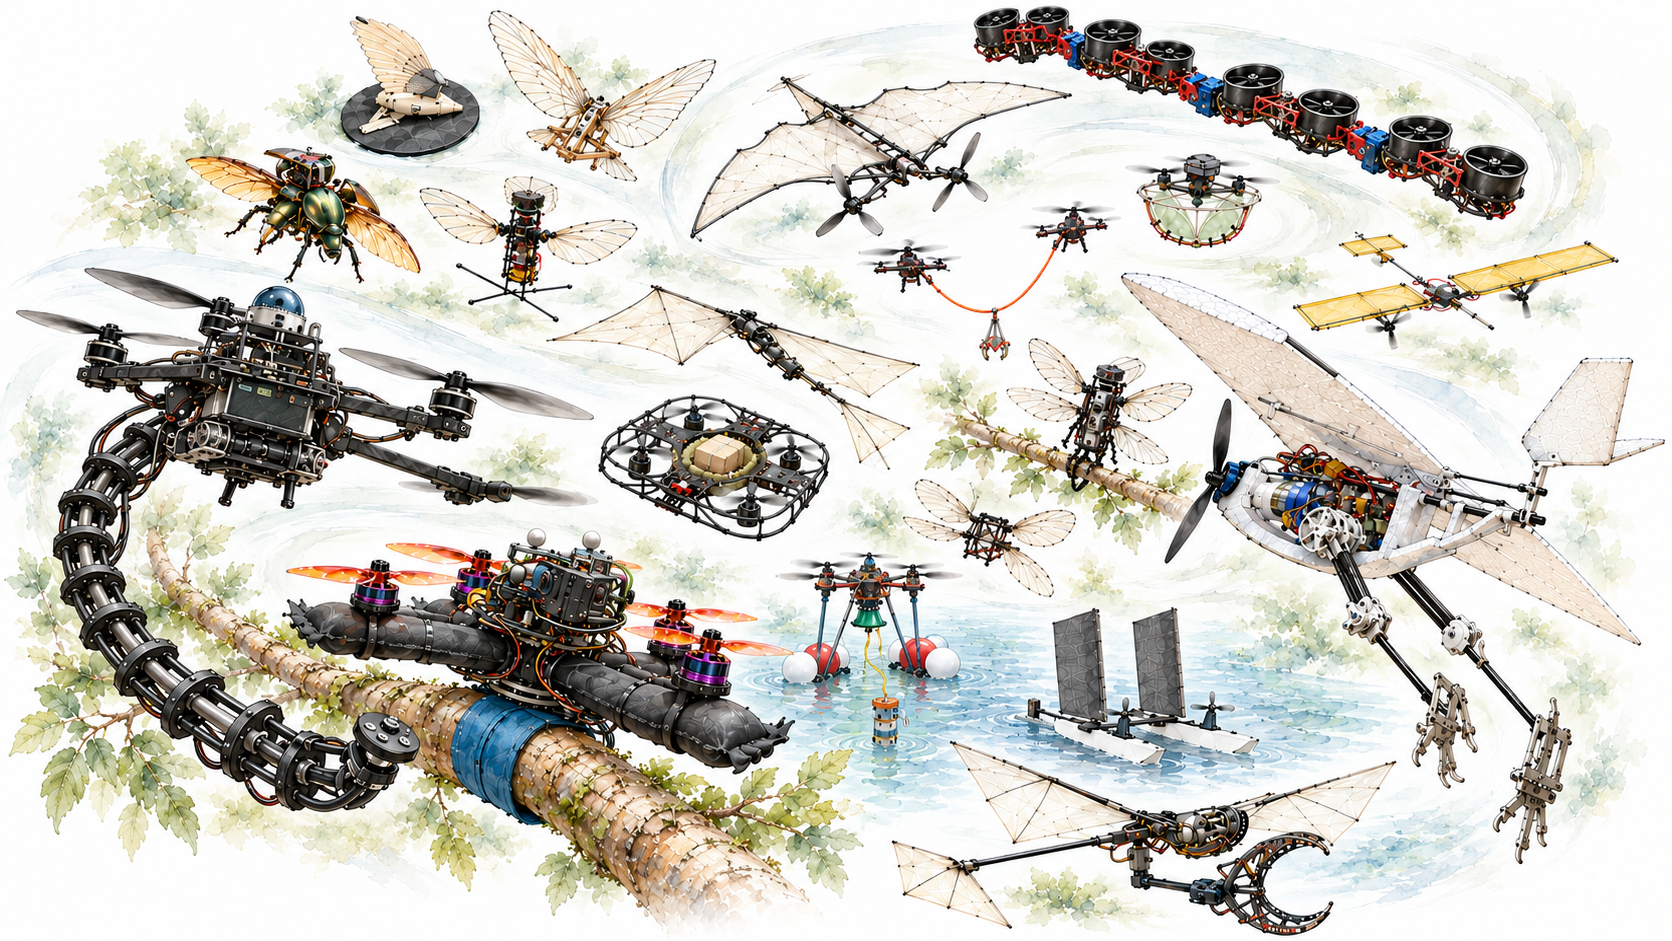
The hero brings together nineteen research contributions associated with the workshop’s proposed speakers and organisers. Each entry below links to the underlying work and its research credits.
Scientific editorial artwork developed with AI assistance from research references. The composition is illustrative: relative sizes and poses are arranged for the ensemble.
Kestrel half-model
Abdulghani Mohamed
RMIT; Mario Martinez Groves-Raines, Simon Watkins, Abdulghani Mohamed, Shane Windsor
Research source ↗Cyborg beetle
T. Thang Vo-Doan
T. Thang Vo-Doan, Van Than Dung and Hirotaka Sato, A Cyborg Insect Reveals a Function of a Muscle in Free Flight, Cyborg and Bionic Systems (2022), Fig.1, DOI 10.34133/2022/9780504
Research source ↗SquirrelDrone
Salua Hamaza
Liming Zheng, Alexander van Zuijlen and Salua Hamaza, Nature Communications 17,6365 (2026), Fig.1
Research source ↗Rope manipulator pair
Chiara Gabellieri
Antonio González-Morgado, Sander Smits, Guillermo Heredia, Anibal Ollero, Alexandre Krupa, François Chaumette, Fabien Spindler, Antonio Franchi and Chiara Gabellieri, Multi-robot Aerial Soft Manipulator For Floating Litter Collection (2025 preprint; 2026 AIS)
Research source ↗eDrone sampler
Stefano Mintchev
Emanuele Aucone, Steffen Kirchgeorg, Alice Valentini, Loïc Pellissier, Kristy Deiner, Stefano Mintchev
Research source ↗Passive-wing microrobot
Hoang-Vu Phan
Hoang-Vu Phan, Hoon Cheol Park and Dario Floreano, Nature 632,1067–1072 (2024), Fig.4
Research source ↗DRAGON
Moju Zhao
Moju Zhao, Kei Okada and Masayuki Inaba, Versatile articulated aerial robot DRAGON: Aerial manipulation and grasping by vectorable thrust control, IJRR (2022 online/2023 print), Figs1 and3
Research source ↗Butterfly ornithopter
Hiroto Tanaka
Hiroto Tanaka and Isao Shimoyama, Forward flight of swallowtail butterfly with simple flapping motion, Bioinspiration & Biomimetics 5,026003 (2010), DOI 10.1088/1748-3182/5/2/026003; photograph from Tanaka Aero/Aqua Biomimetics Lab research page
Research source ↗Aerial–aquatic flapper
Raphael Zufferey
Robot research: R. Zufferey, S. Jeger, M. Hüsser, F. Ruiz, A. Lapsansky, A. Ijspeert, D. Floreano. Reference photographs © Raphael Zufferey.
Research source ↗Centerless grasper
Huichan Zhao
Yu Herng Tan, Wenjie Li, Huichan Zhao, IJRR (2025)
Research source ↗AET continuum arm
Peng Lu
Rui Peng, Yu Wang, Minghao Lu and Peng Lu / University of Hong Kong
Research source ↗RAVEN
Dario Floreano
Research: Won Dong Shin, Hoang-Vu Phan, Monica A. Daley, Auke J. Ijspeert and Dario Floreano. Reference photographs supplied by the user; photographer credit not supplied.
Research source ↗Bistable wing robot
Pakpong Chirarattananon
Ruihan Jia, Songnan Bai, Song Li, Fangzheng Wang, Hongqiang Wang, Pakpong Chirarattananon
Research source ↗SoBAR
Pham Huy Nguyen
Pham H. Nguyen, Karishma Patnaik, Shatadal Mishra, Panagiotis Polygerinos and Wenlong Zhang
Research source ↗MEDUSA
Mirko Kovač
Aerial Robotics Lab / Imperial College London; pod close-up credit Empa
Research source ↗SailMAV
Andre Farinha
André Farinha, Luca Romanello, Raphael Zufferey, Jenna Lawson, Sophie Franziska Armanini and Mirko Kovač
Research source ↗Soft microrobot
YuFeng (Kevin) Chen
Courtesy of the researchers, via MIT News. Research team: MIT Soft and Micro Robotics Laboratory and collaborators.
Research source ↗Nimble+ perching flapper
Sophie Armanini
Krispin C. V. Broers and Sophie F. Armanini; Flapper Nimble+ airframe by Flapper Drones
Research source ↗GRIFFIN P-Flap
Aníbal Ollero
Raphael Zufferey, Jesus Tormo-Barbero, Daniel Feliu-Talegón, Saeed Rafee Nekoo, José Ángel Acosta and Anibal Ollero
Research source ↗